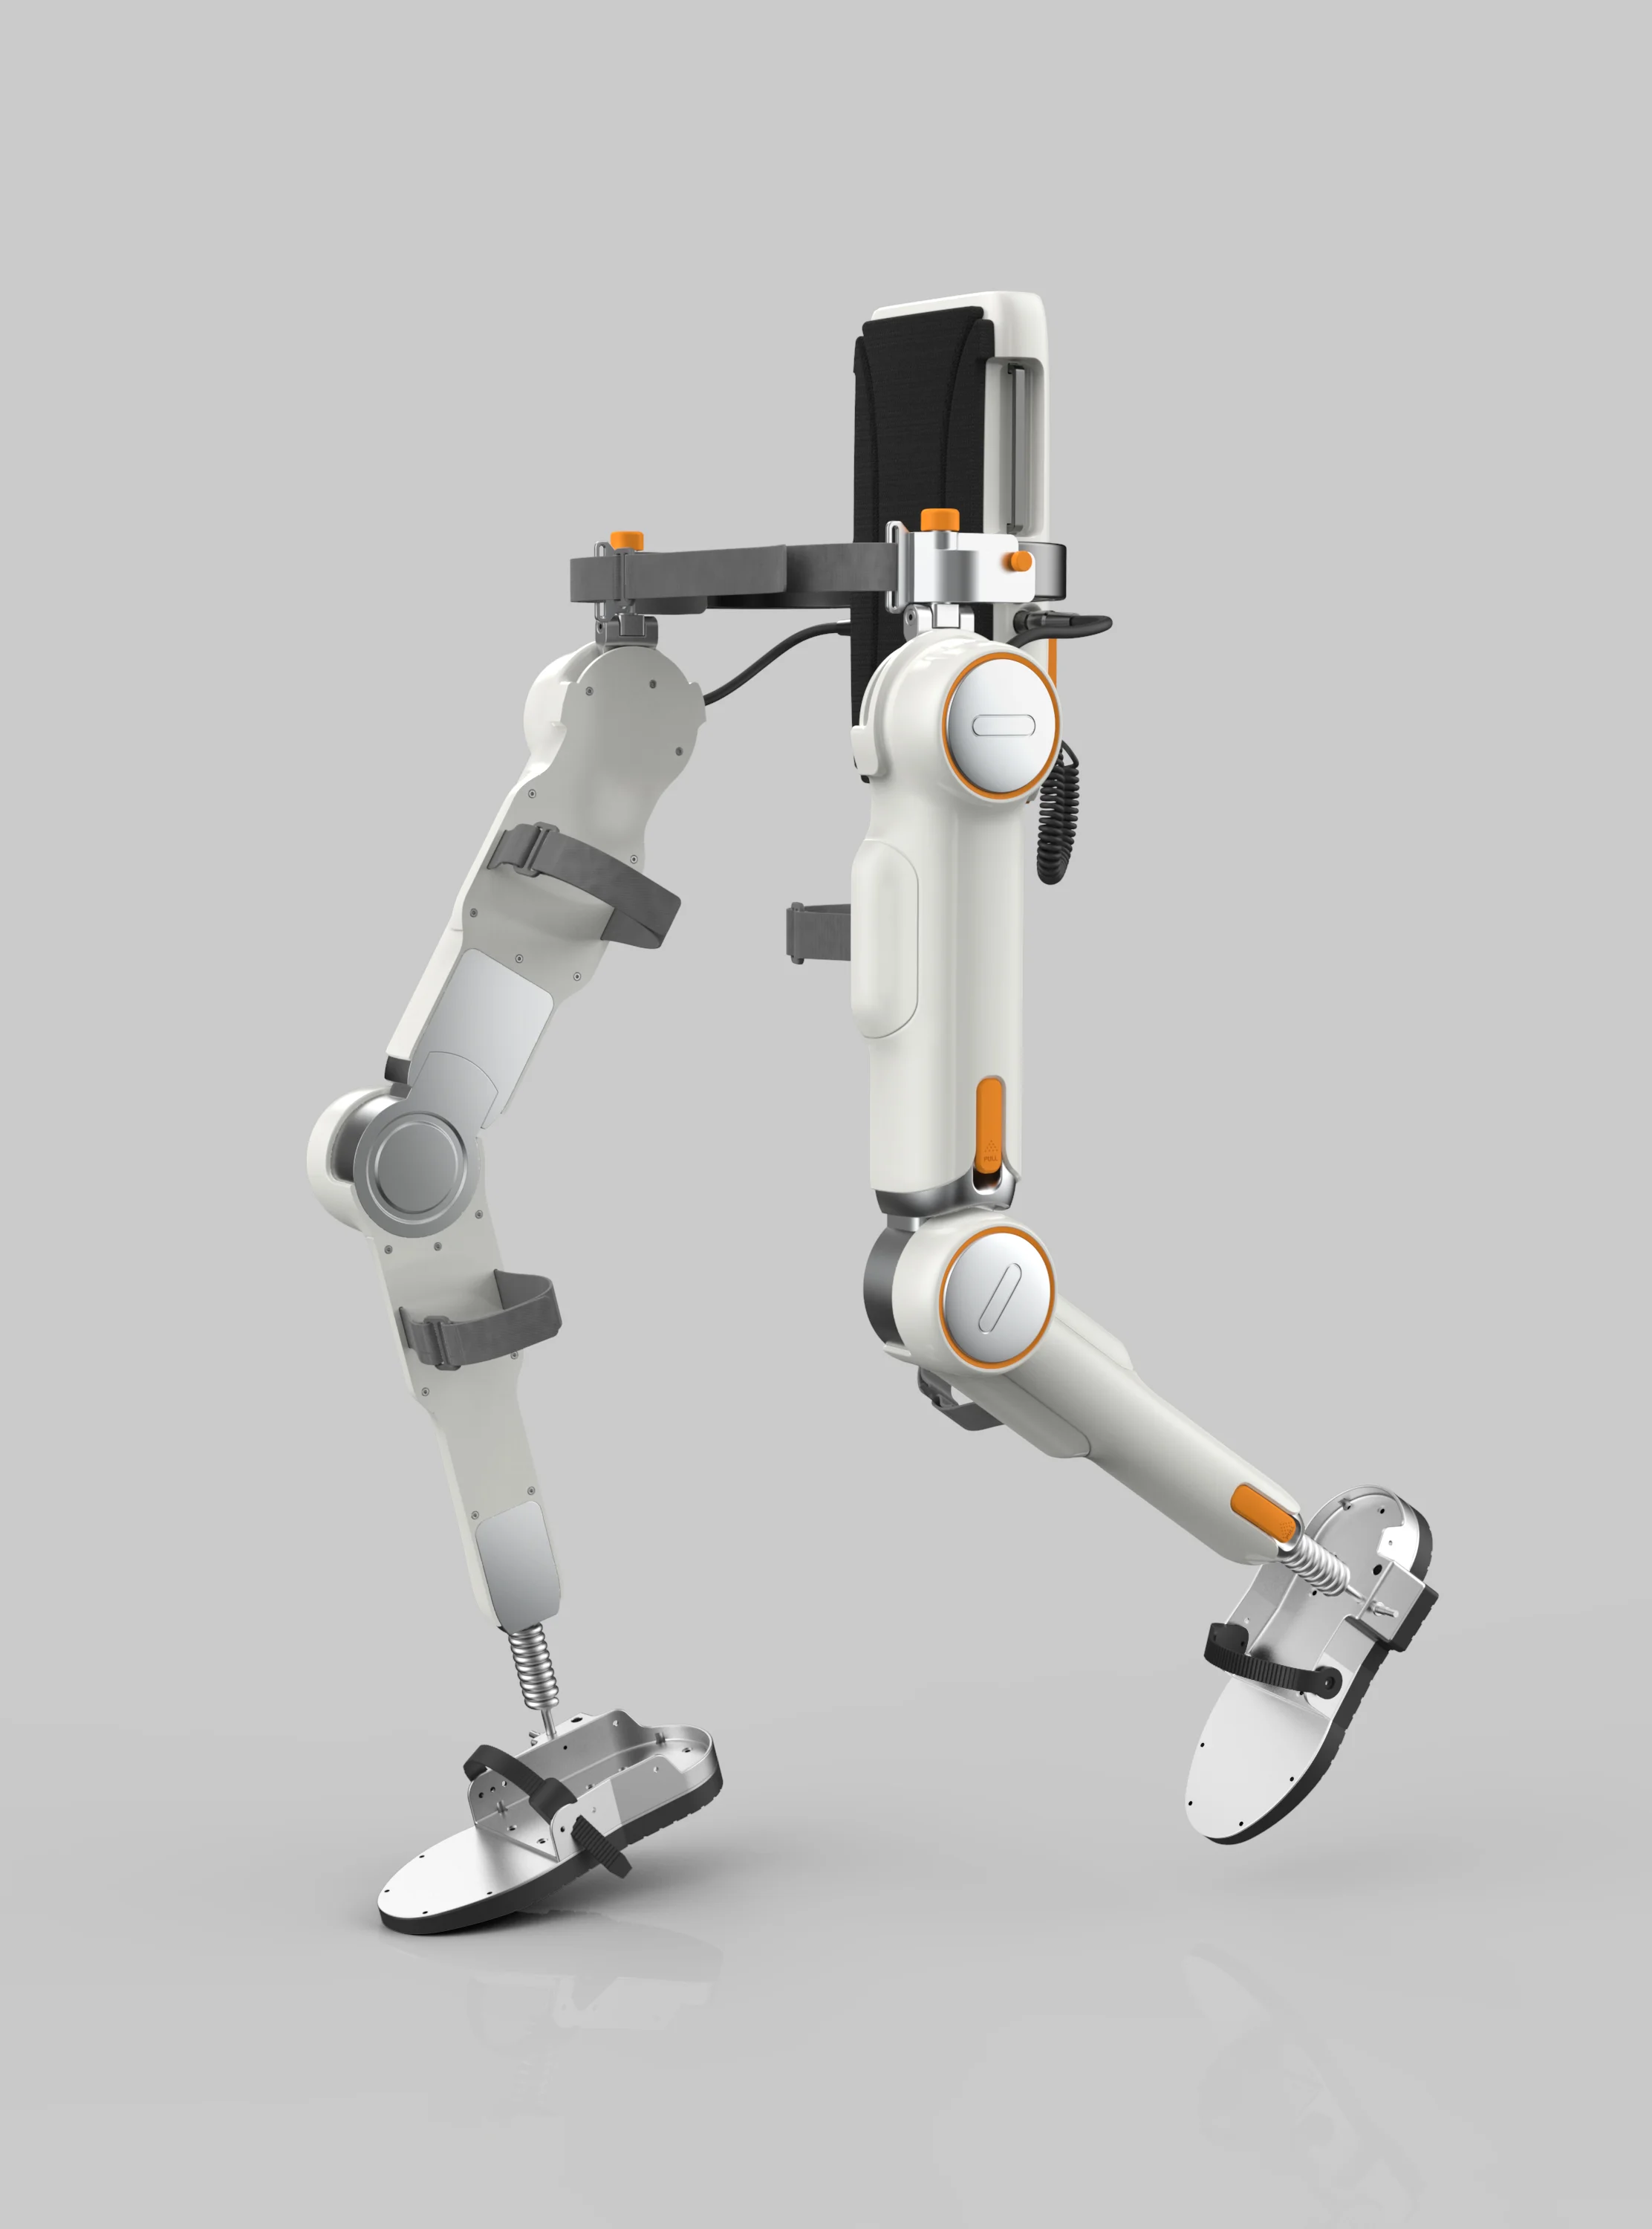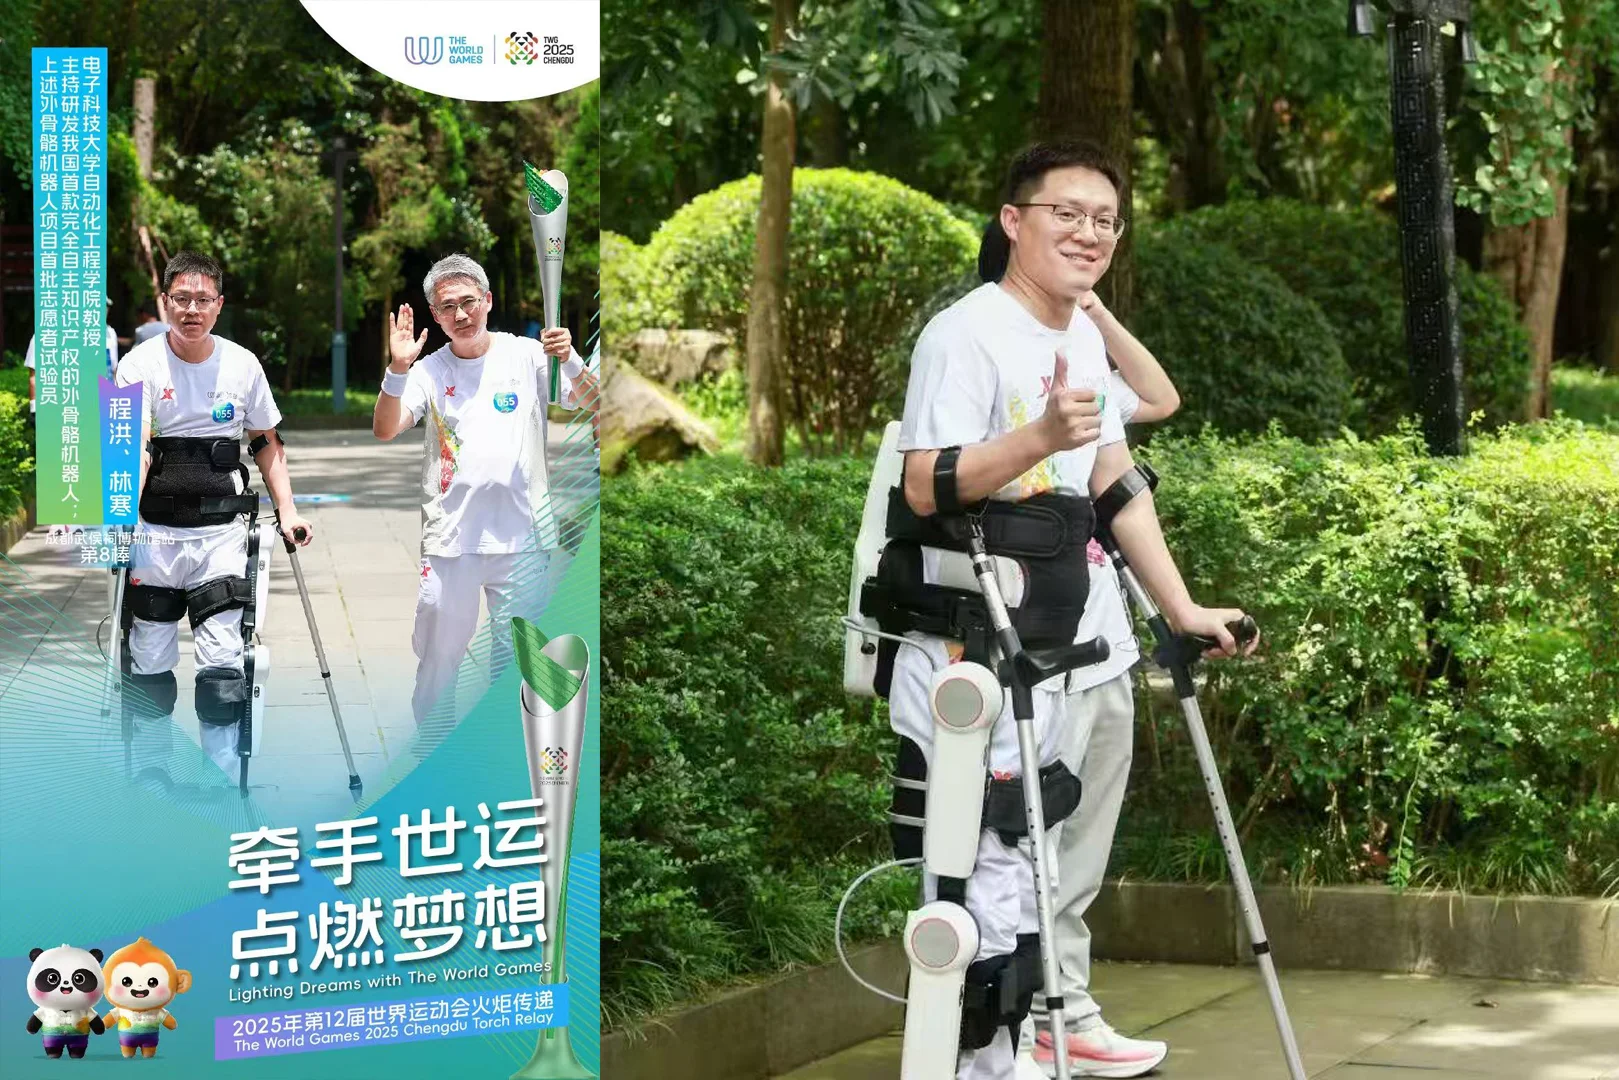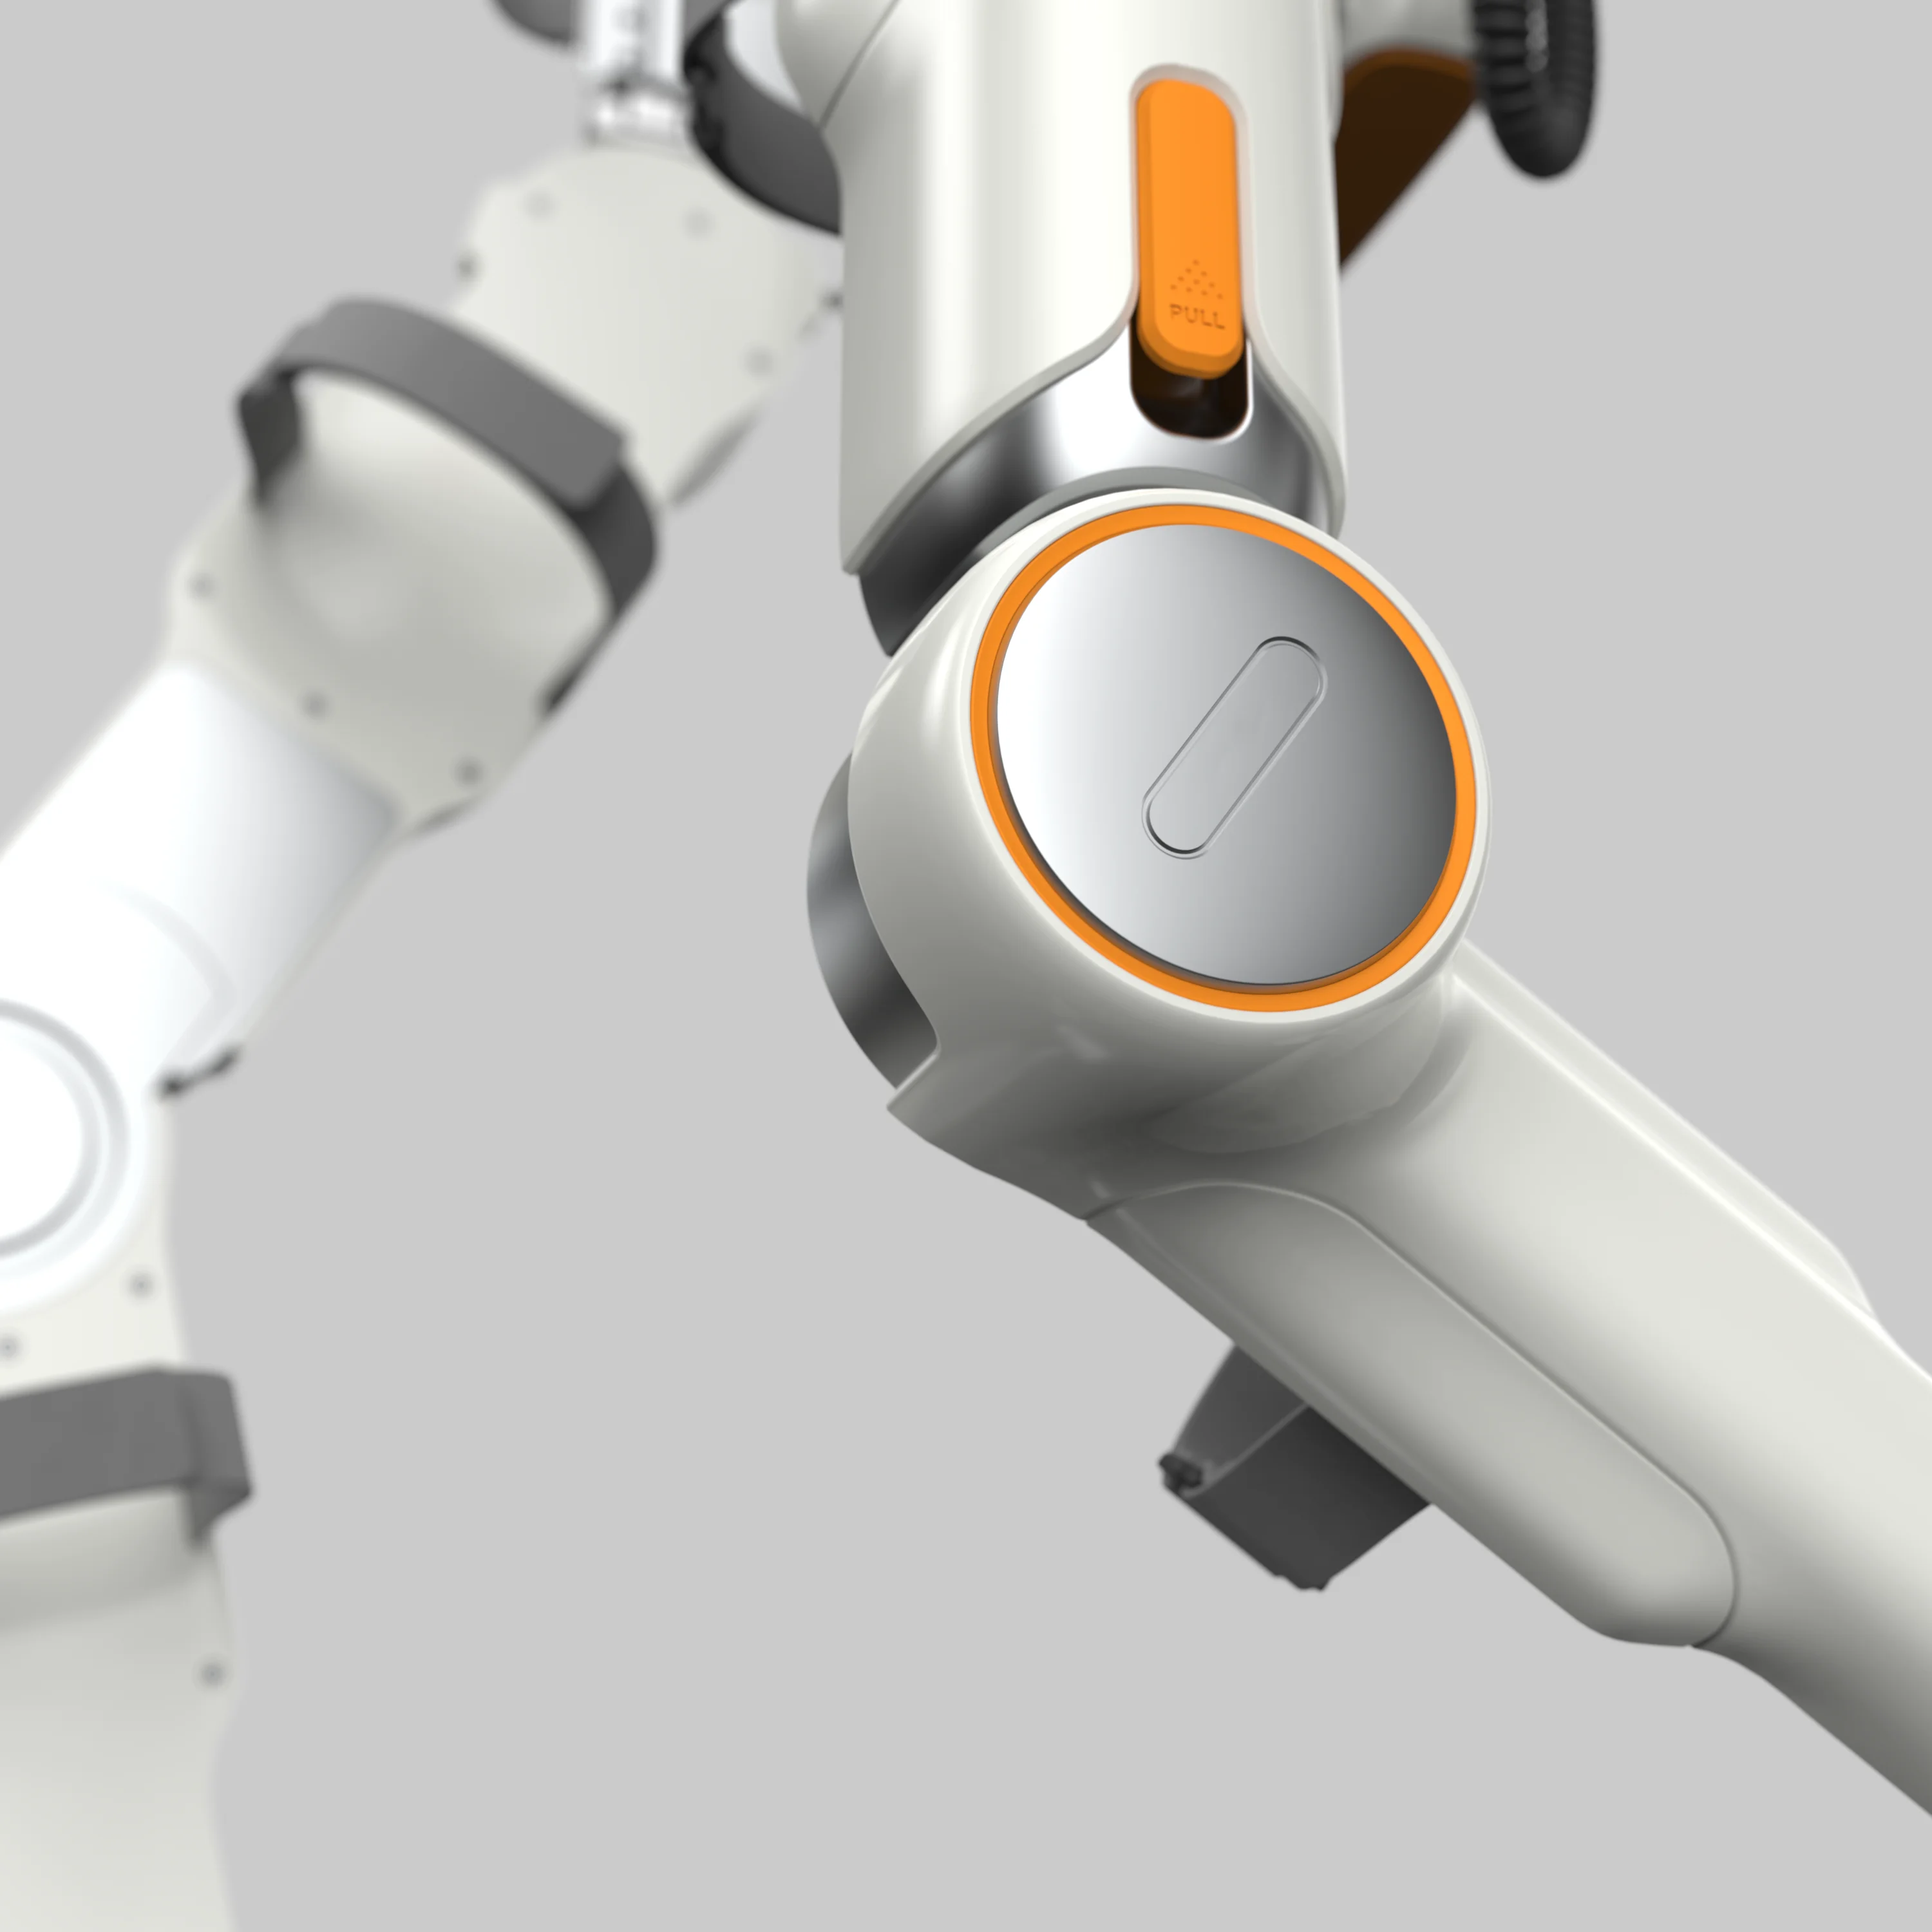
Lower Limb Exoskeleton
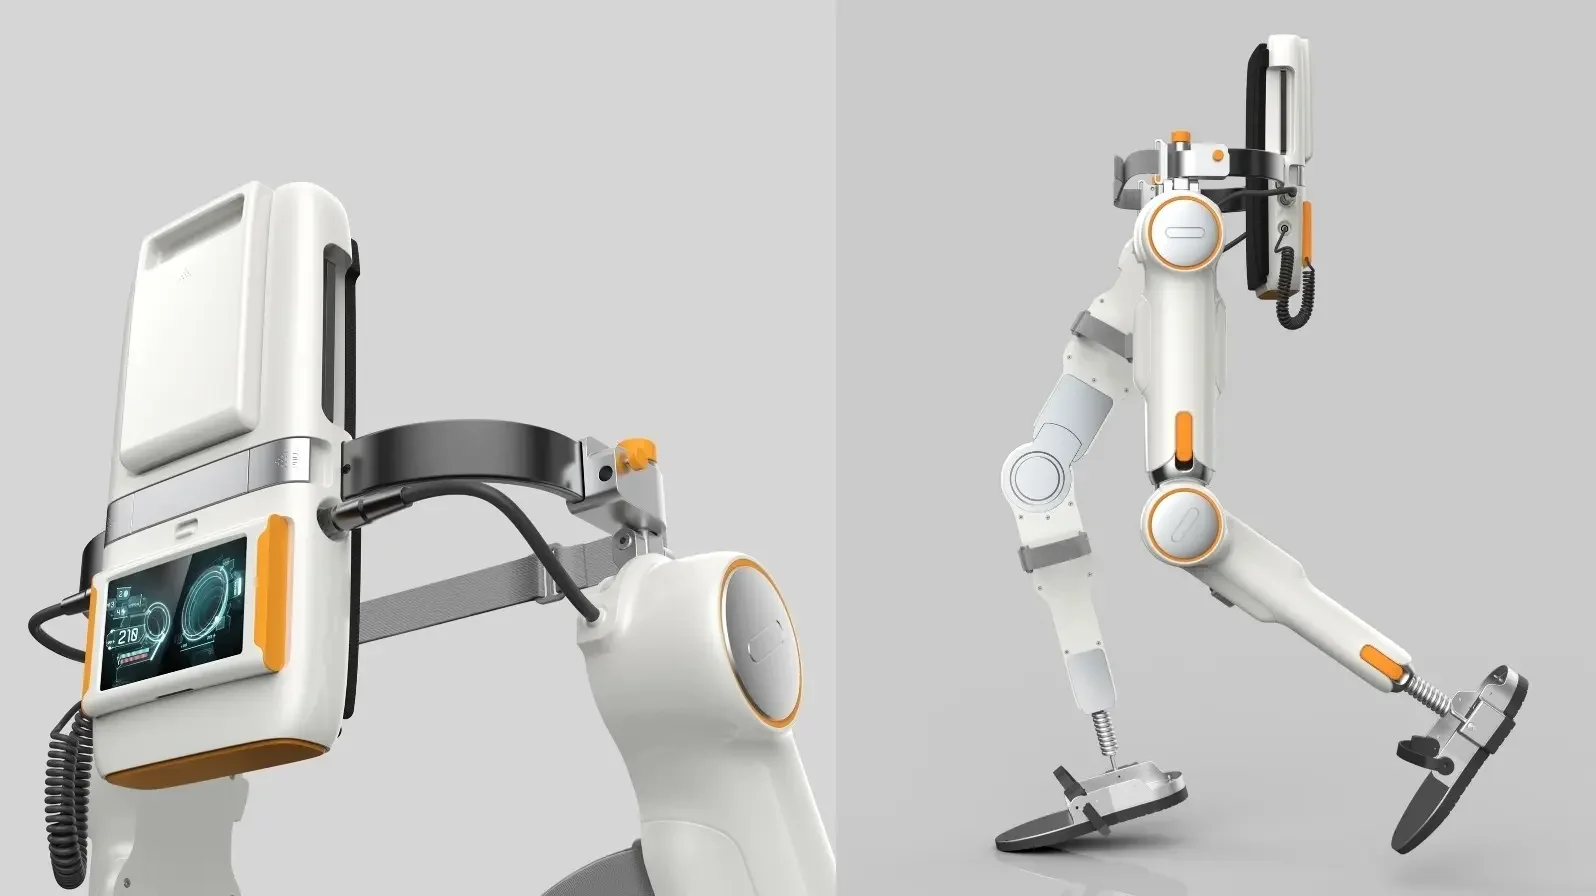
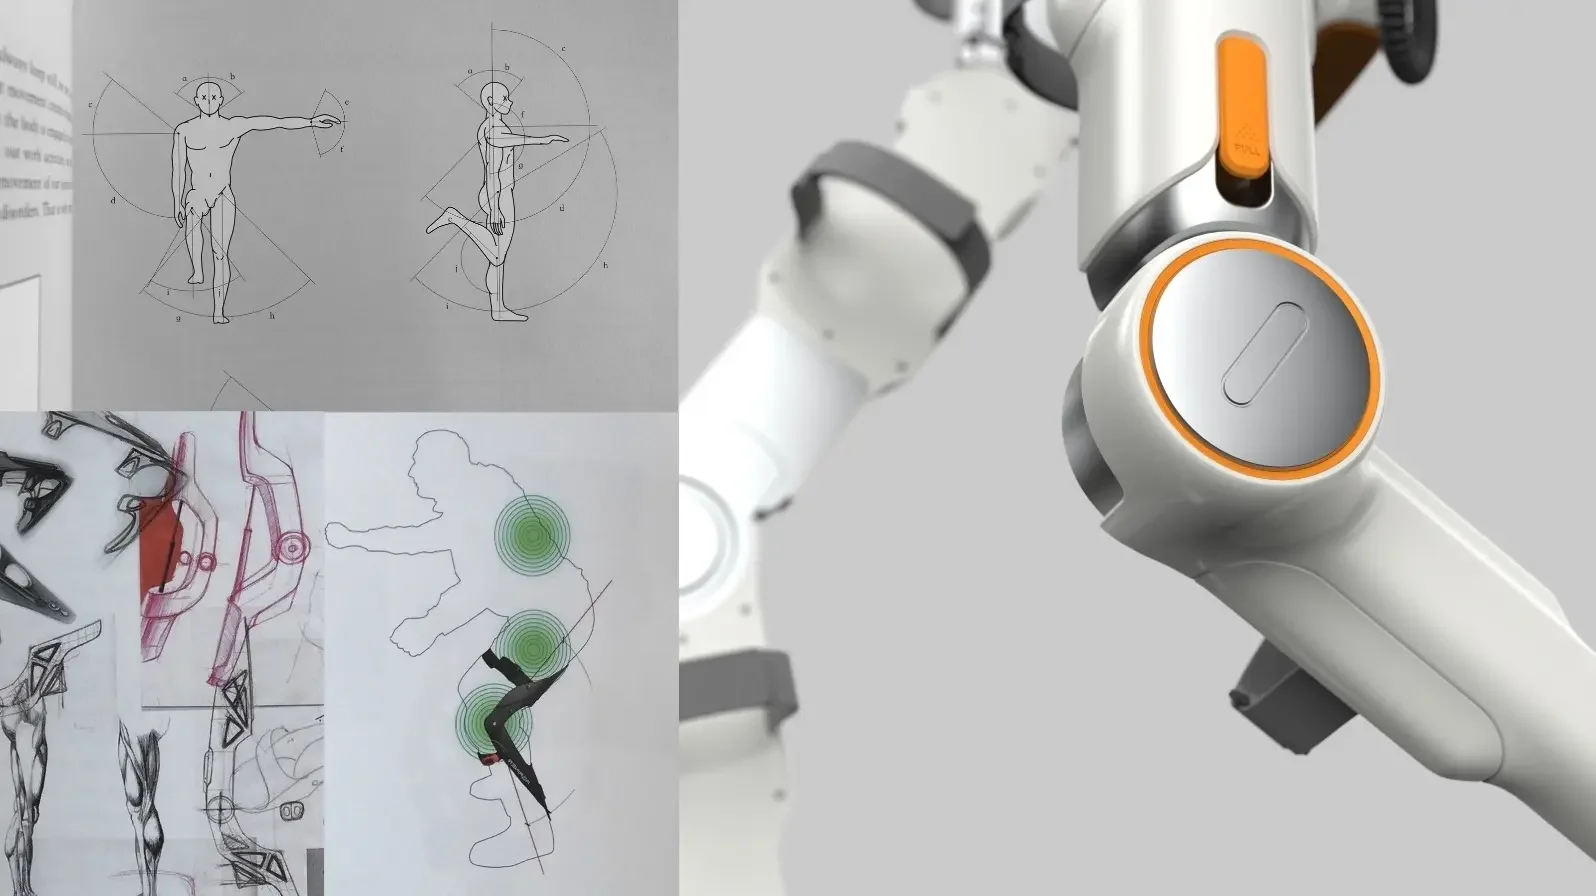
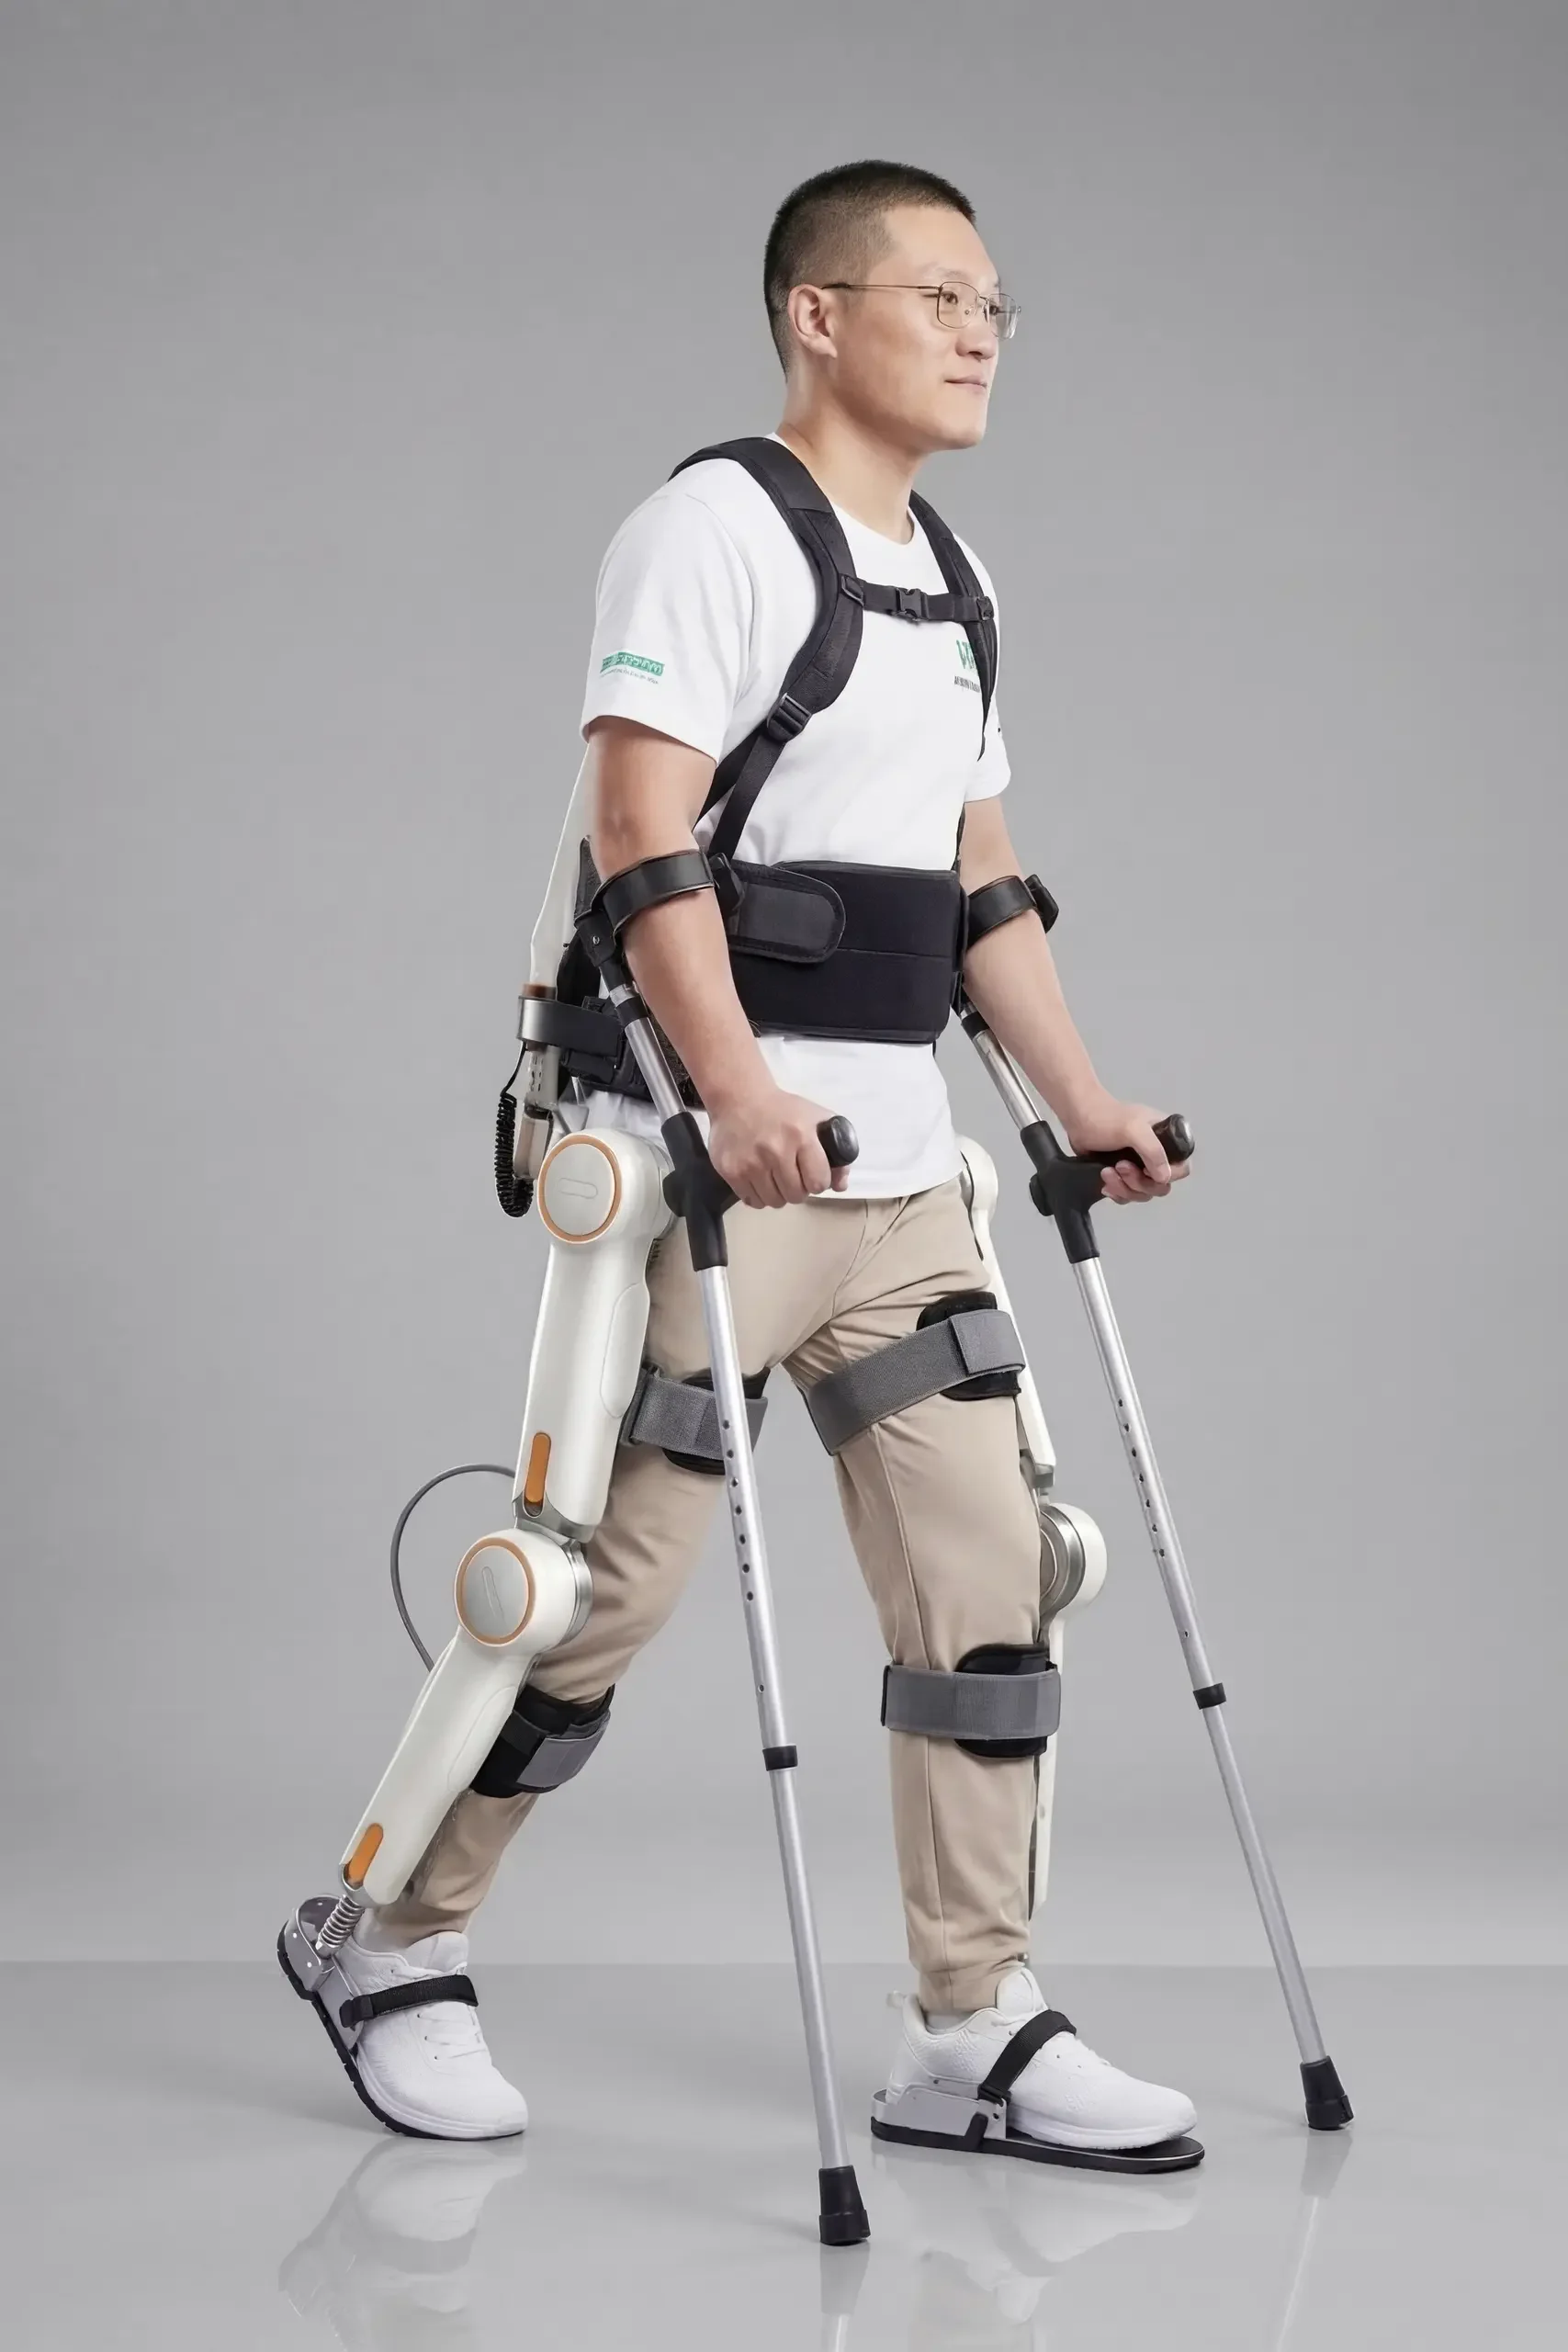
An active lower-limb exoskeleton developed with the University of Electronic Science and Technology of China for rehabilitation assistance, improving walking stability and motion control. Its shell must follow human kinematics.
The hip, knee and ankle axes each need their own kinematics, and the shell must stay rigid across different leg lengths while remaining ready for production.
IDING DESIGN built a parametric leg-length fit model, estimated knee fatigue life early, built the molding parting direction into the form and simulated the donning path. It won a Golden Panda Award.